上海机器人研究所
上海机器人研究所
主页
新闻
研究
论文
获奖
成员
联系
Edge Contact
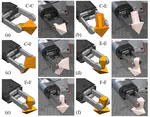
Planning 6-D Grasps for Two-Finger Grippers Considering Edge and Corner Contacts
A CAD-based antipodal grasp planner that explicitly considers edge and corner contacts with soft fingerpads, expanding feasible 6-D grasp configurations beyond face-only planning and improving success rates on diverse objects.
胡正涛
,
Liu Ruishuang
,
Qiu Mocong
,
CHEN Hao
,
杜亮
,
Kiyokawa Takuya
,
WAN Weiwei
,
袁建军
,
Harada Kensuke
Cite
DOI
IEEE Xplore
Cite
×